Multimodal inspection
Prepare, position and transfer parts between 3D scanners, CMMs, vision systems and industrial CT.
NM3D SCANHUMAN · VIRIATO
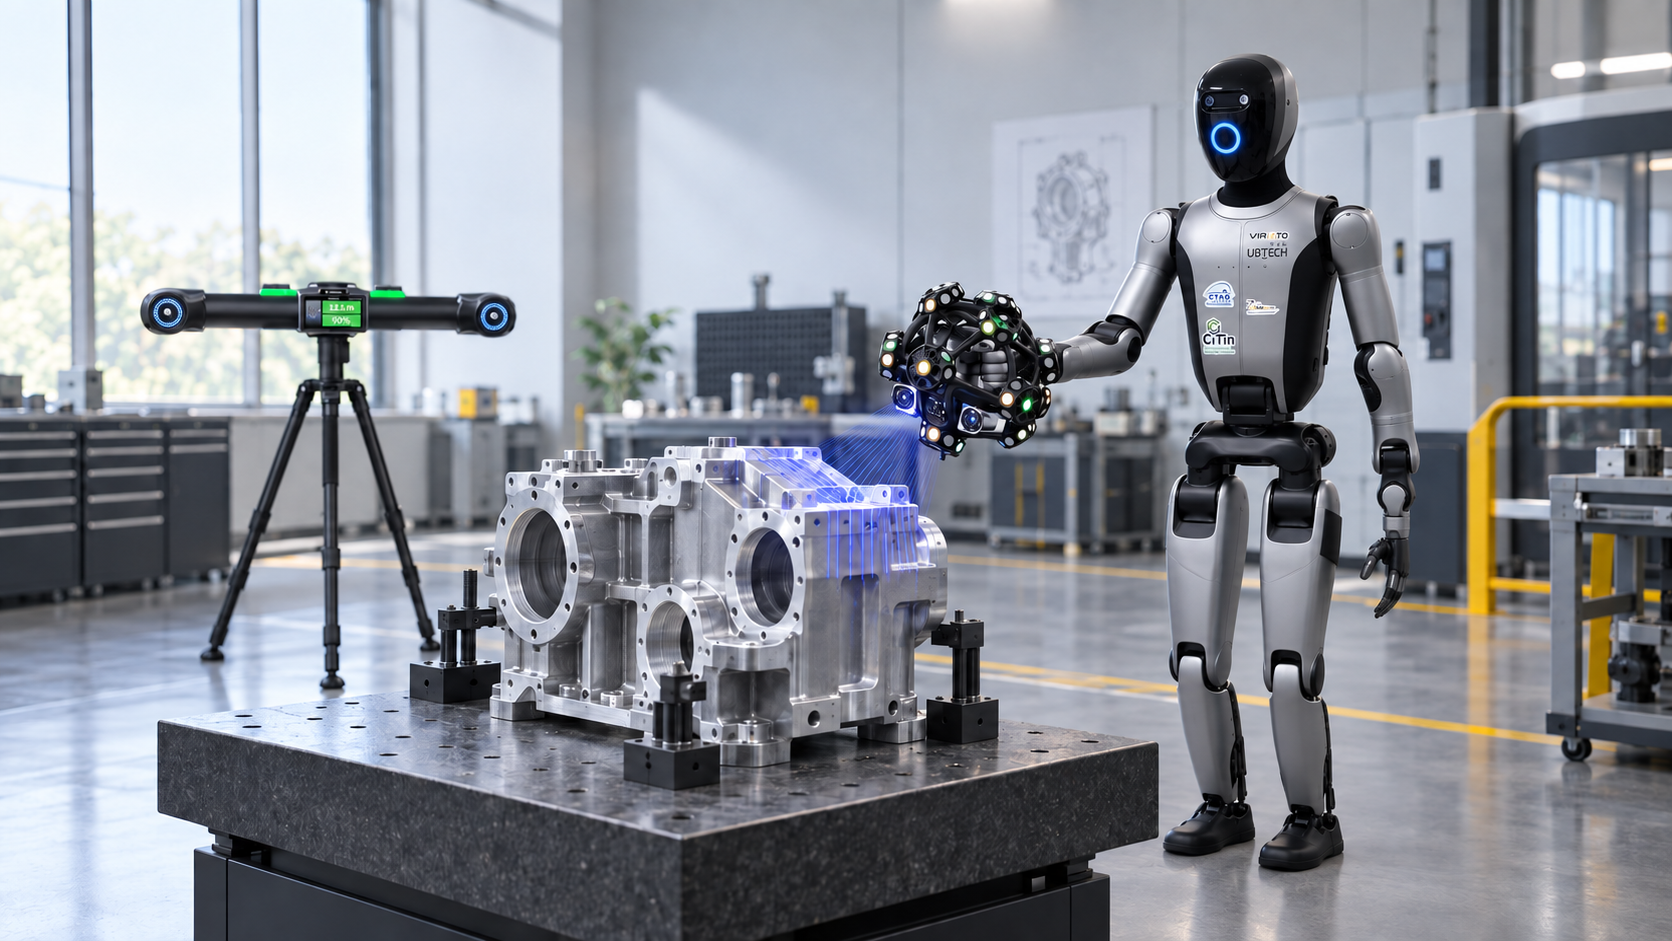
We are developing Viriato, our humanoid based on the UBTECH WALKER S2, to connect robotic handling, 3D metrology and additive manufacturing in more flexible industrial workflows.
THE MISSION
The goal is to research how a humanoid can move parts, interact with different equipment and execute inspection and production sequences, always with safety, traceability and human supervision.
Prepare, position and transfer parts between 3D scanners, CMMs, vision systems and industrial CT.
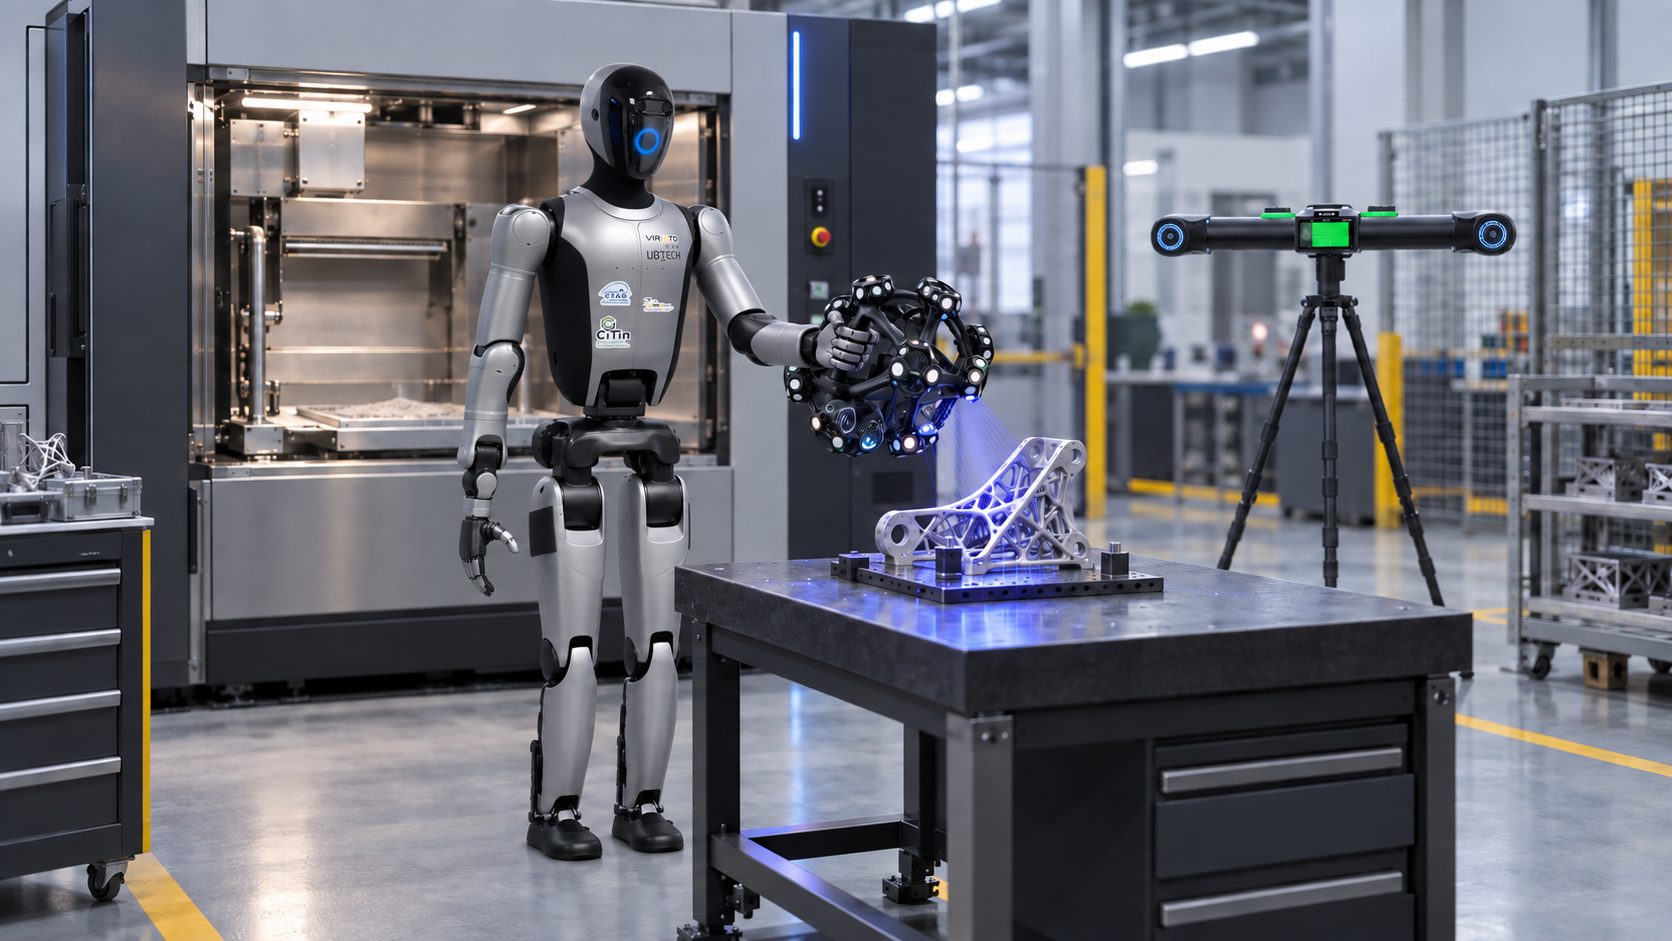
Remove finished parts from 3D printers, identify them and route them to cooling, post-processing or inspection.
Link part, program, result and decision to build a traceable digital process history.
FROM BATCH TO RESULT
TECHNOLOGIES TO INTEGRATE
Fast geometry capture, CAD-to-part comparison and surface analysis.
Loading and unloading, fixture positioning and launch of validated programs.
Safe handling for non-destructive internal and external inspection.
Context recognition, task orchestration and result traceability.
AUTONOMOUS 3D INSPECTION
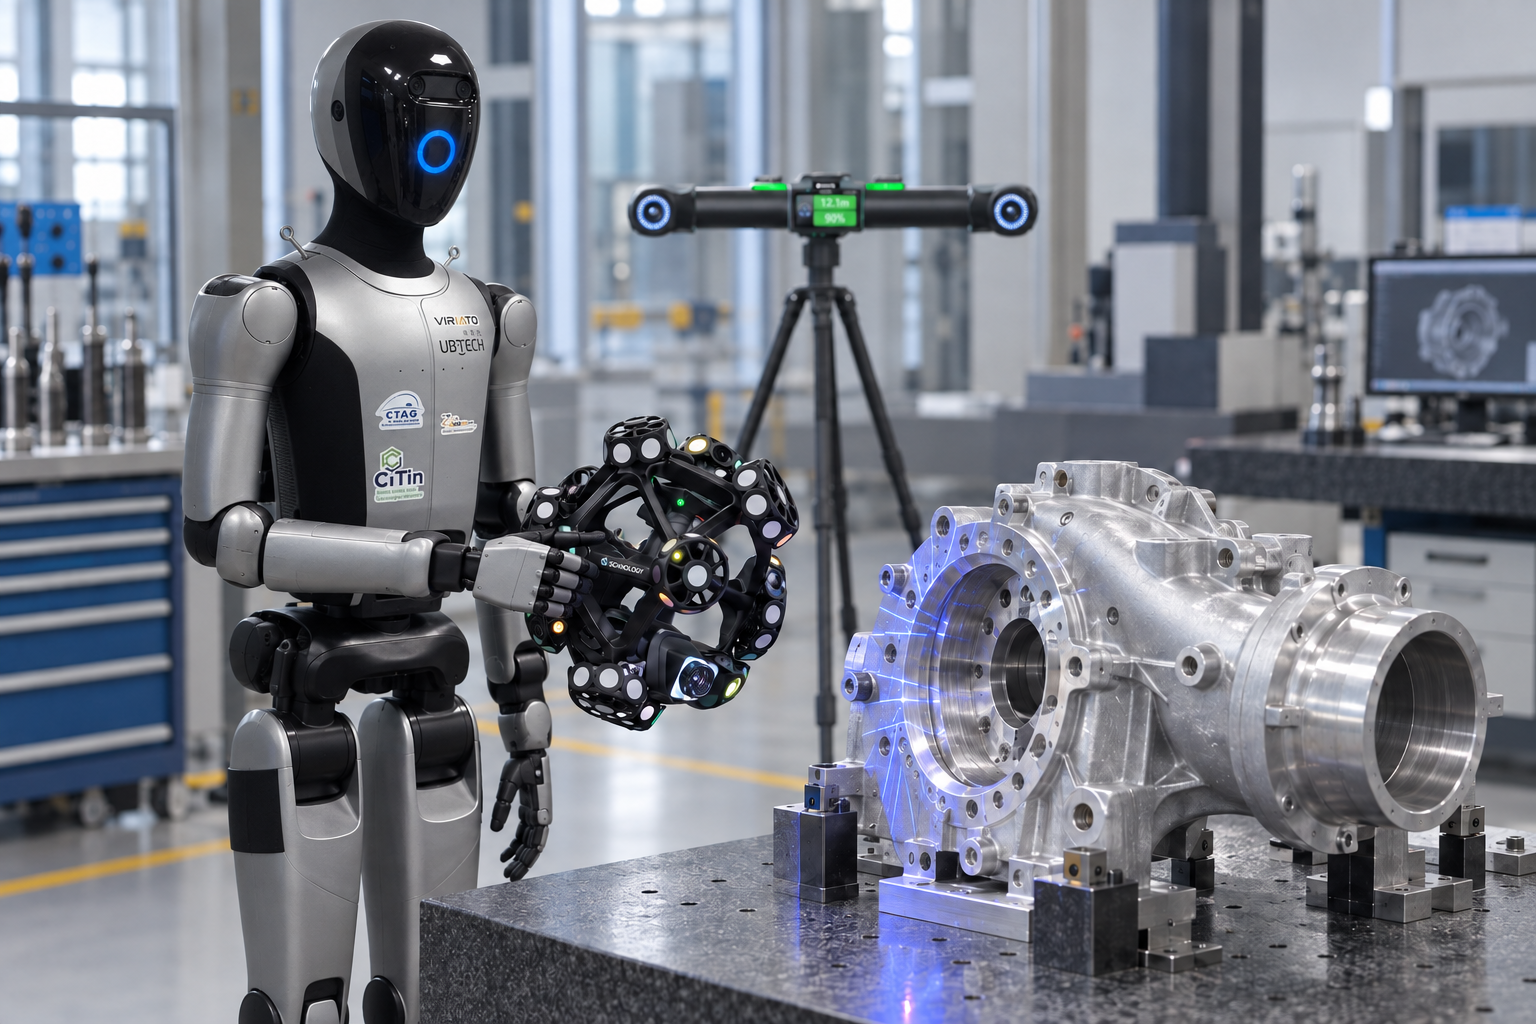
The development integrates perception, motion planning, scanner positioning, optical tracking and data validation to perform repeatable inspections.
R&D concept visualisation based on the real Viriato and real equipment.
ADDITIVE MANUFACTURING
Viriato is being studied as a flexible operator that removes parts when a cycle ends, confirms their identity, places them in a fixture or container and routes them to the defined next step.
Development includes interfaces with different equipment, handling variable geometries, thermal and safety controls, error management and communication with production and quality systems.
ROADMAP
FAQ
No. It is an NM3D R&D development being built and validated in stages.
Viriato is the name NM3D gives to its WALKER S2 humanoid robot within the ScanHuman project.
Compatibility is assessed case by case according to interfaces, geometry, safety and process. The research targets a modular architecture, not a promise of universal compatibility.
INDUSTRIAL COLLABORATION
Share the part, equipment, current sequence and desired outcome. NM3D can assess how the case fits the development programme.