Ambientes desenhados para pessoas
Stairs, low postures, operations at different heights and tasks requiring whole-body mobility.
Walker S2 e Walker Tienkung →Industrial humanoid robotics · Humatrix + UBTECH
From material handling to inspection, remote operation, customer service and embodied-AI research: we select, integrate and support the right platform for each task.
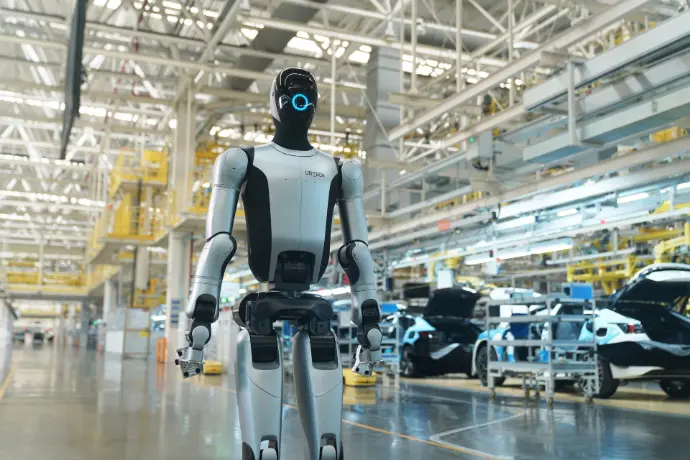
Start with the task
Humanoid form is not an end in itself. We choose legs, wheels, lifting, hands or grippers according to the route, payload, cycle, environment and system in which the robot will work.
Stairs, low postures, operations at different heights and tasks requiring whole-body mobility.
Walker S2 e Walker Tienkung →Predictable movement on industrial floors, long operating autonomy, rotation in narrow aisles and logistics integration.
Cruzr S2, Cruzr Y1 e Sky Walker →Open interfaces, ROS 2, teleoperation, data collection, VLA/VLM and development of proprietary capabilities.
Tienkung e Tienkung DEX →Robots and applications
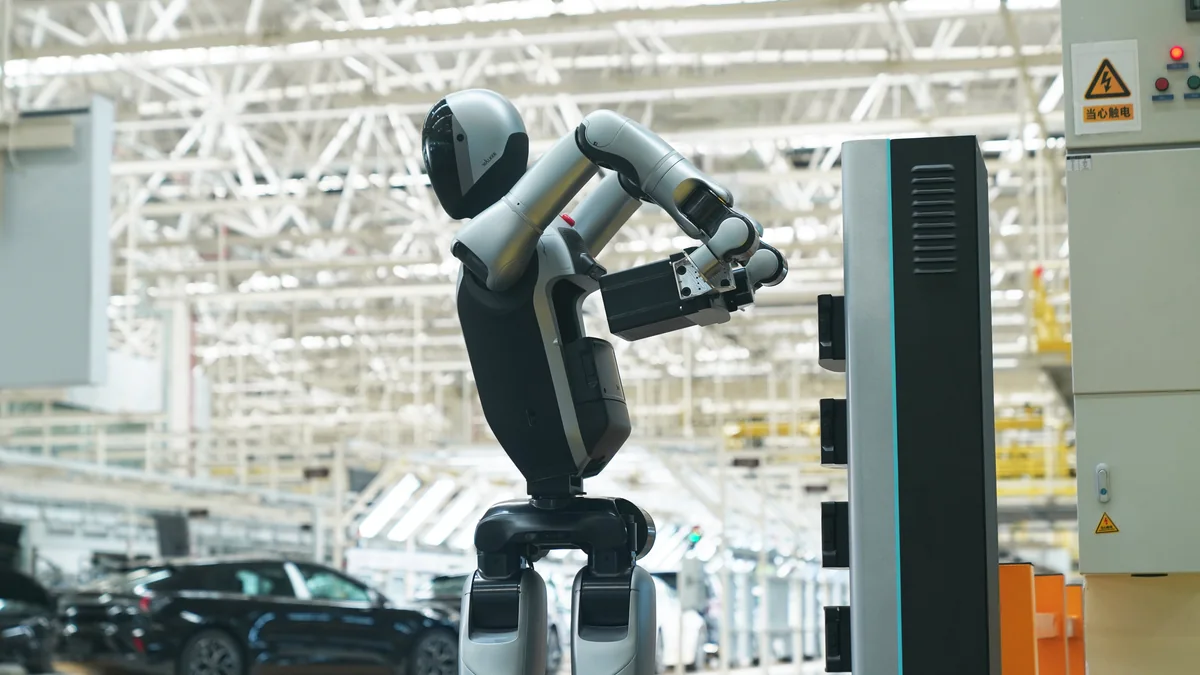
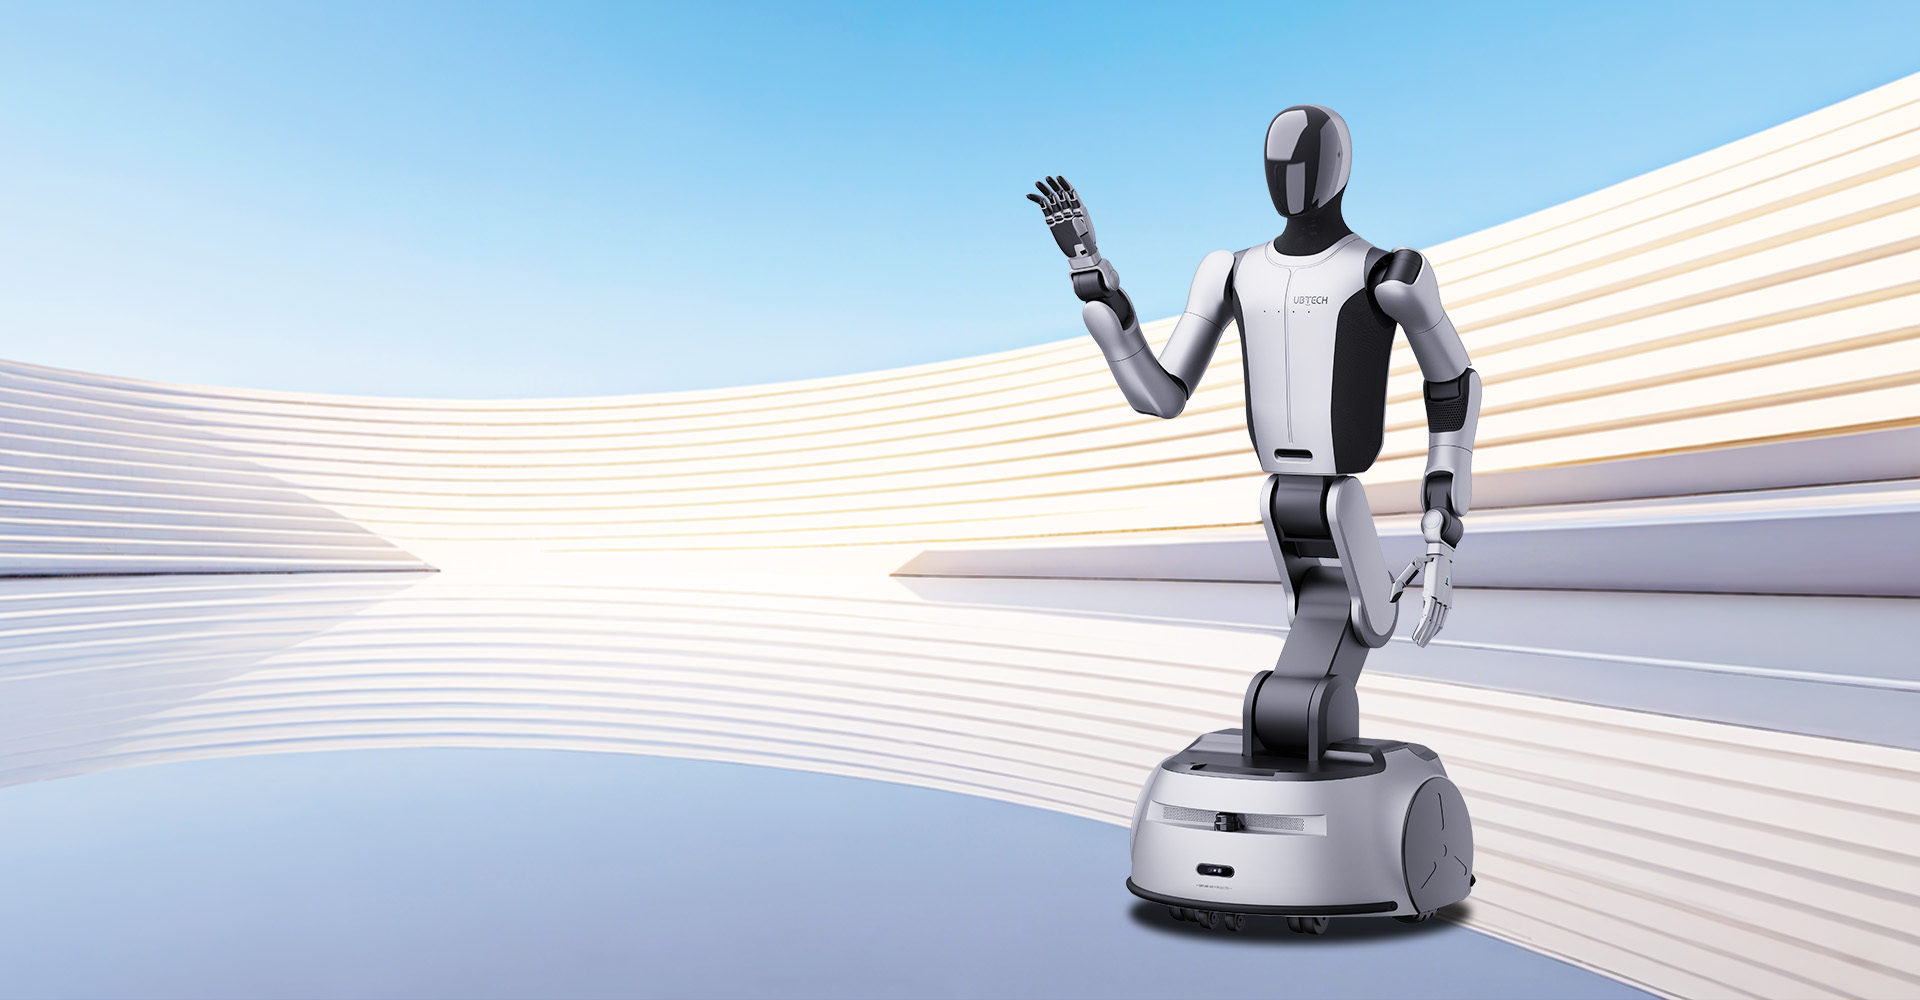
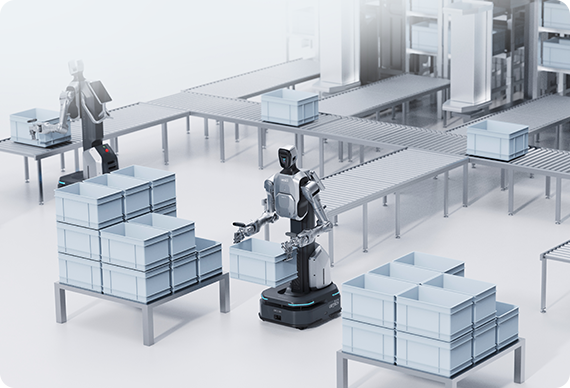
Models for production, logistics, inspection, service and research, with application photographs and official platform and application images.
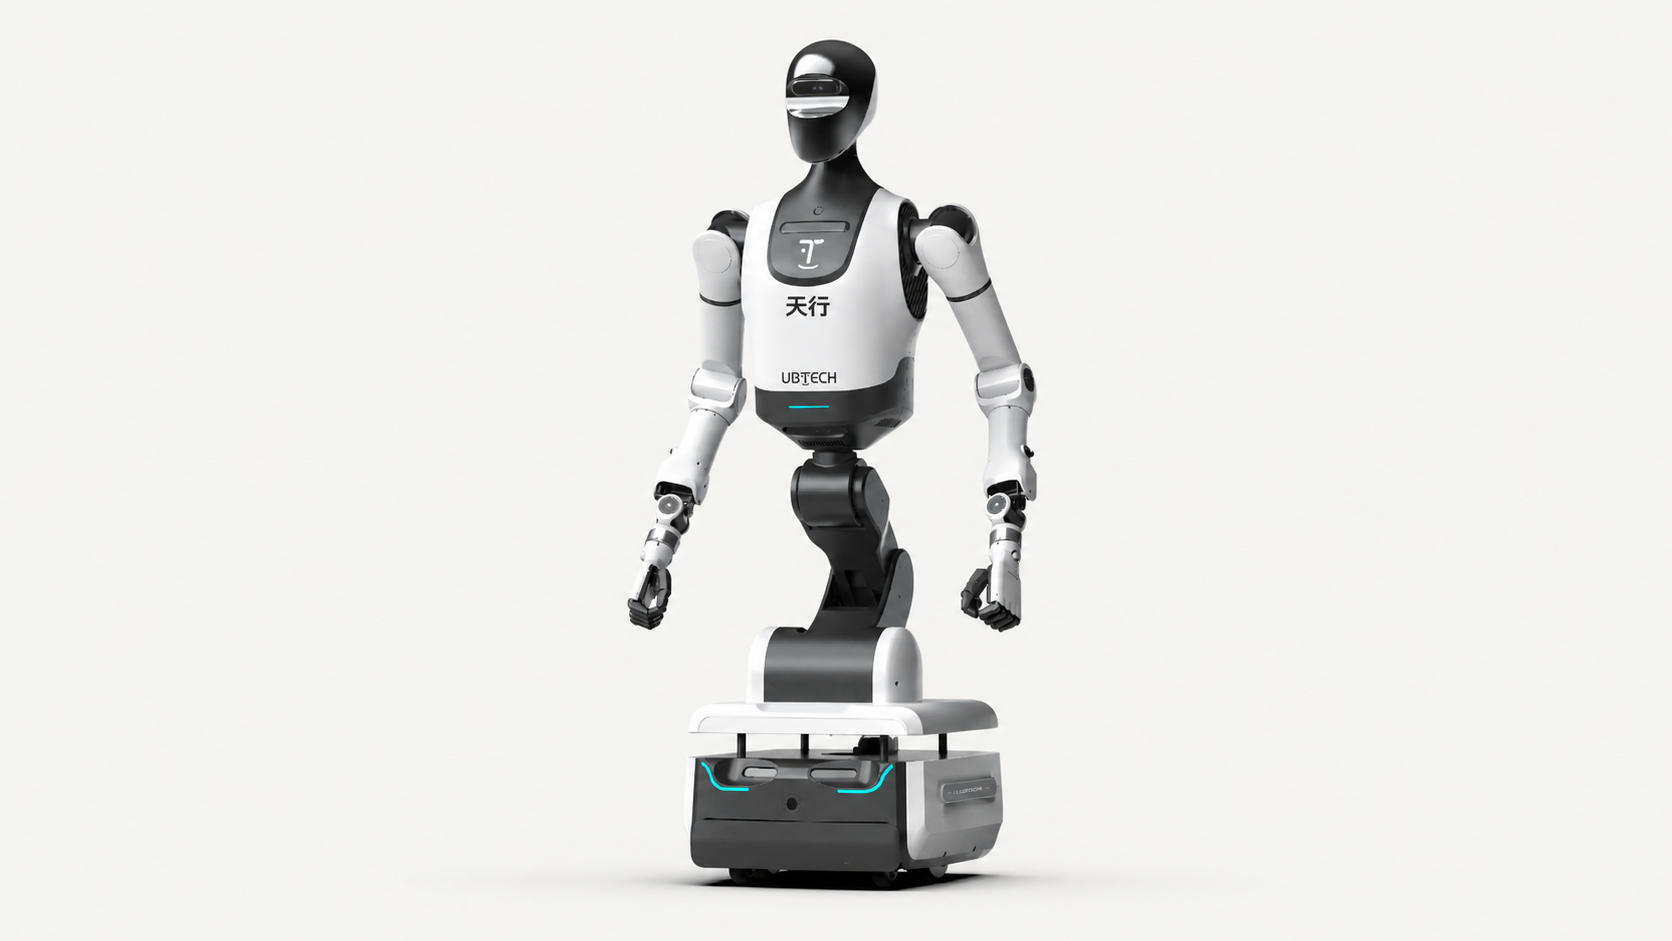

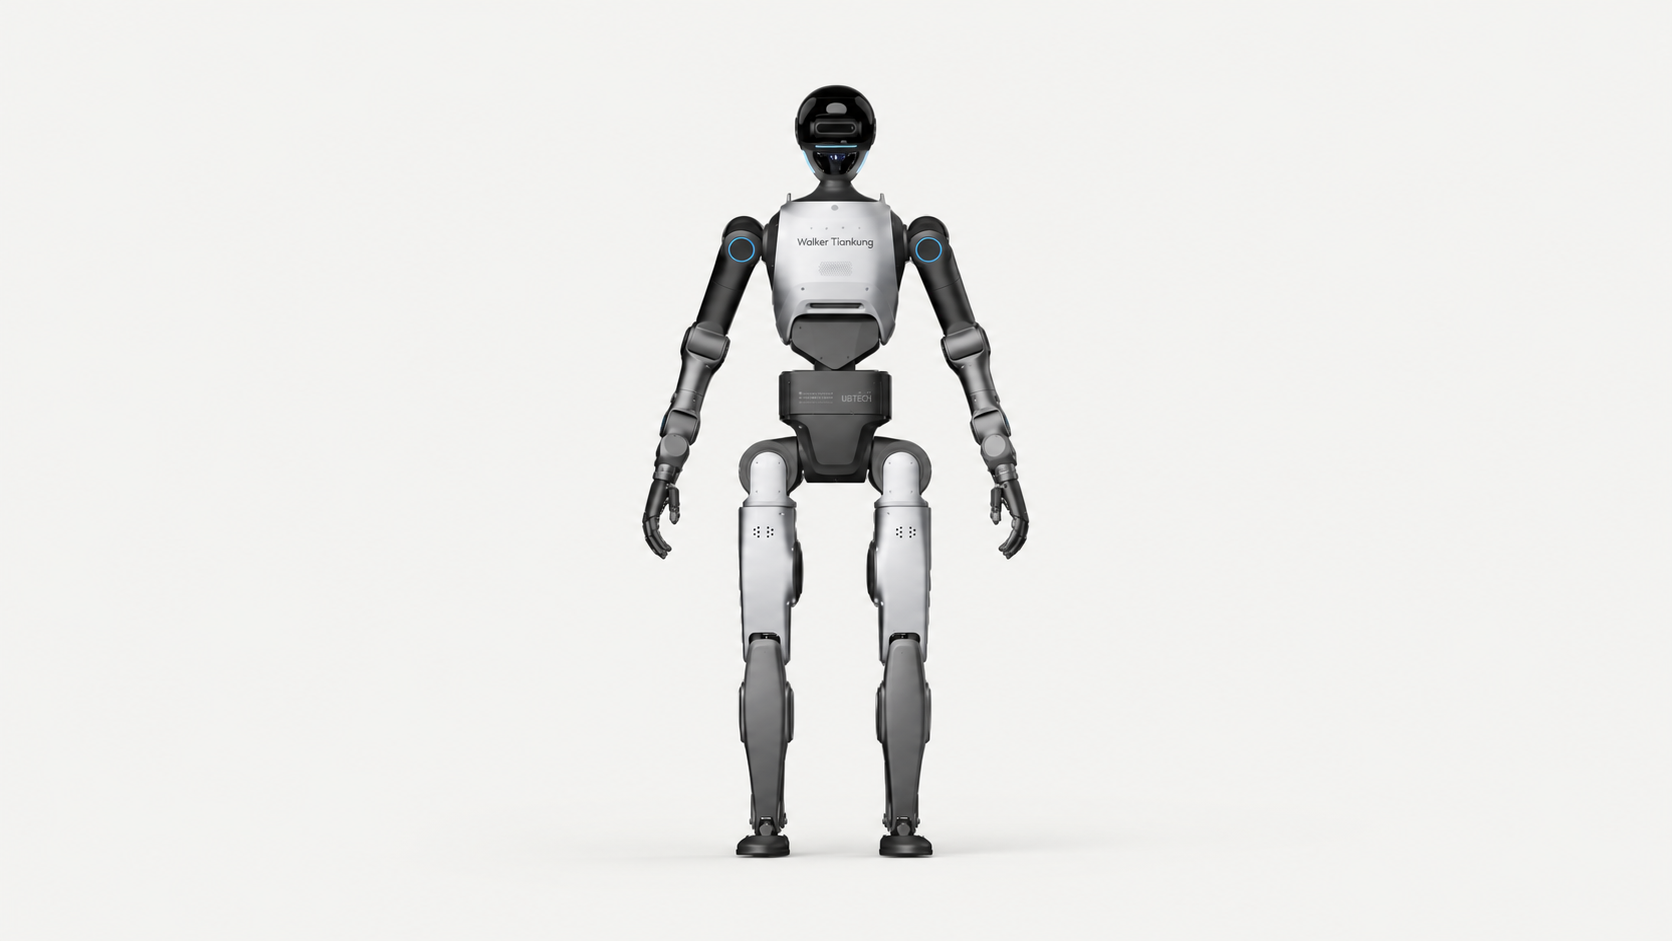
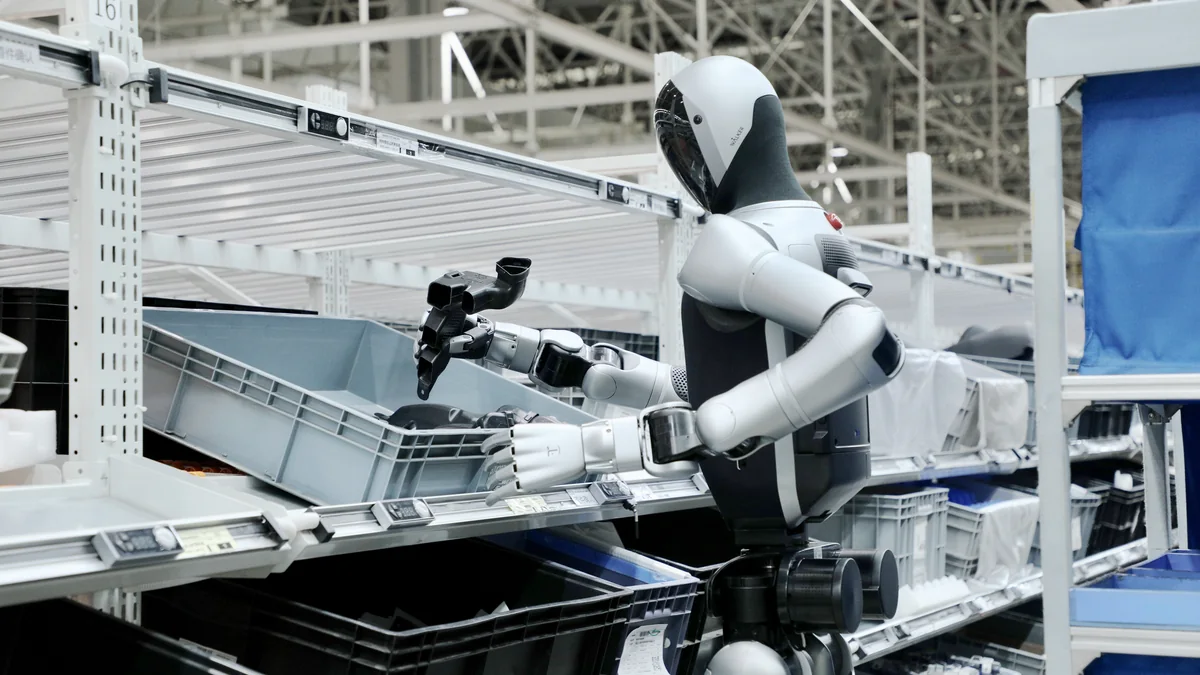
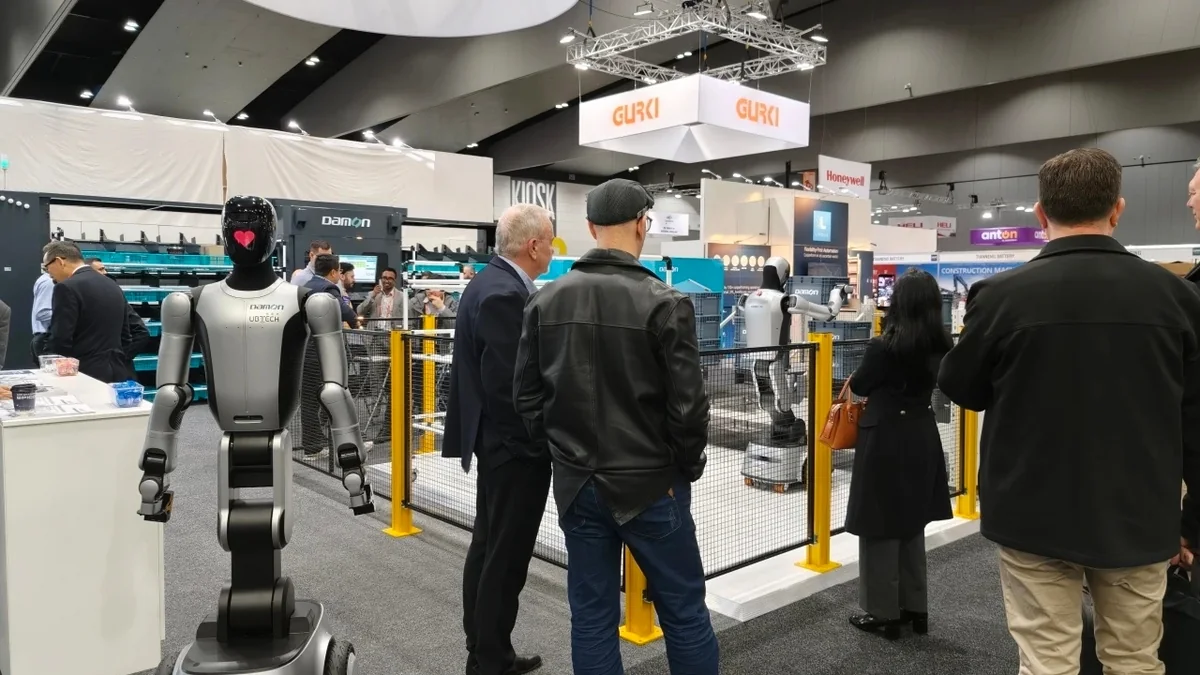
Gama Humatrix
The values shown depend on configuration, hands, gripper, batteries and software package. NM3D validates the combination for the application.
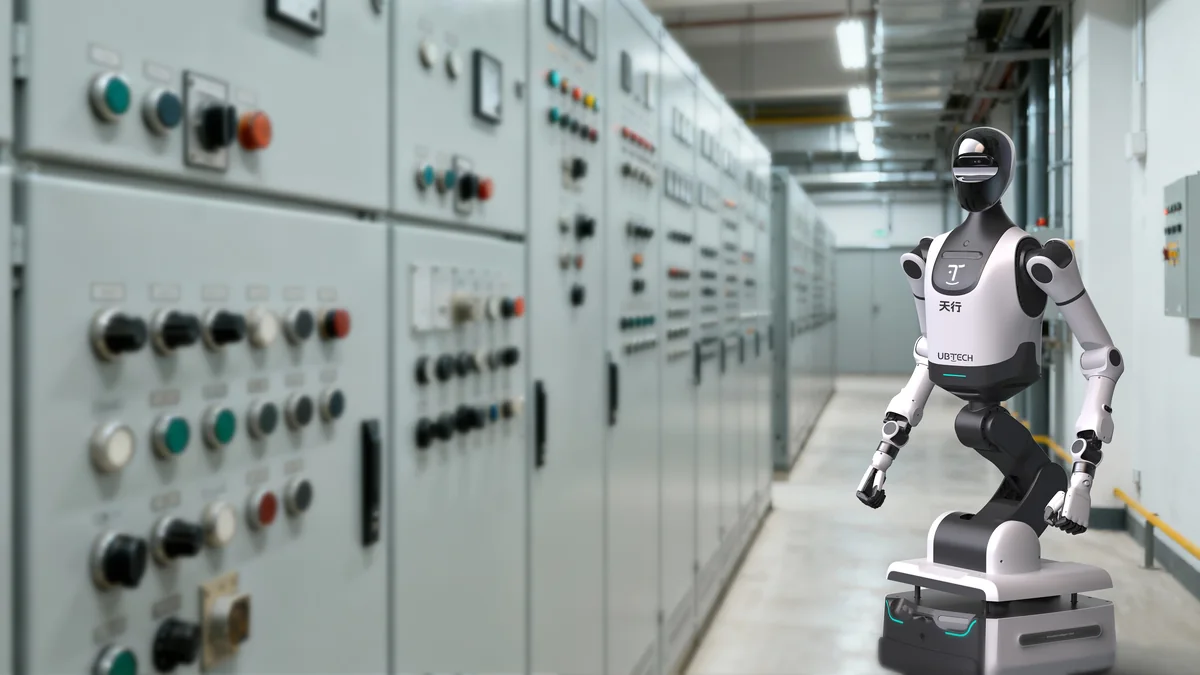
A full-size industrial humanoid for handling, transport, SPS, inspection, assembly and work in less structured production environments. Battery management supports continuous operation with autonomous replacement.
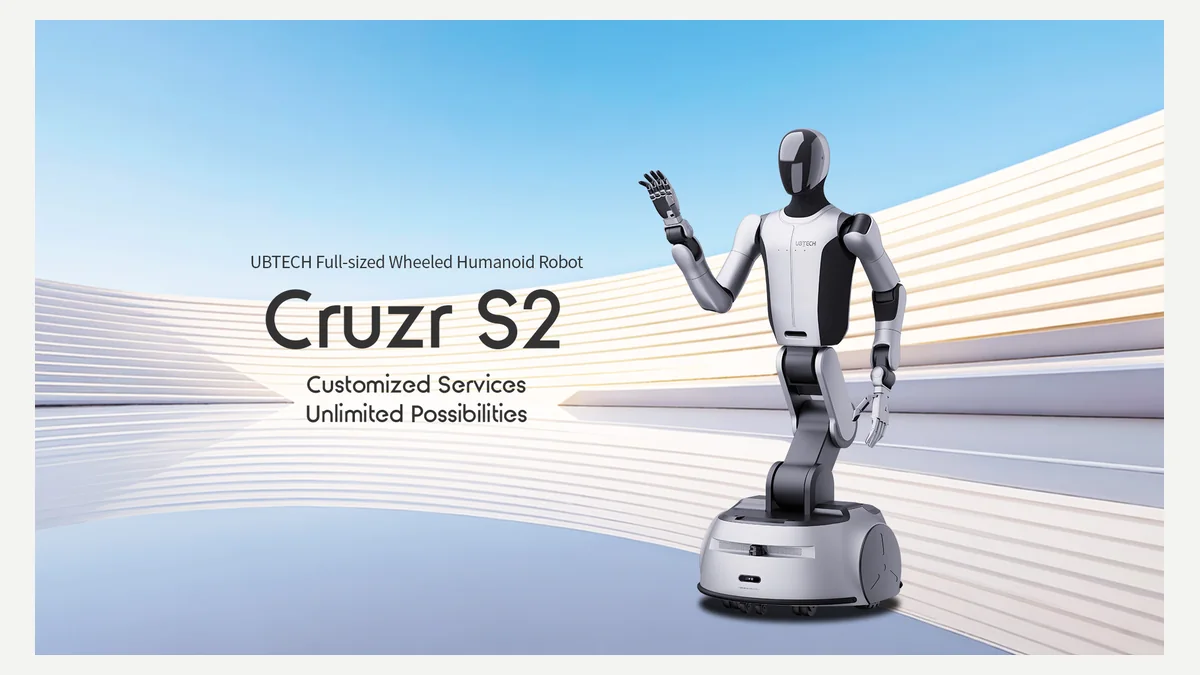
A full-size humanoid with a mobile base, folding torso and lifting capability for operation in narrow aisles. It combines manipulation at different heights with autonomous navigation and long operating autonomy.
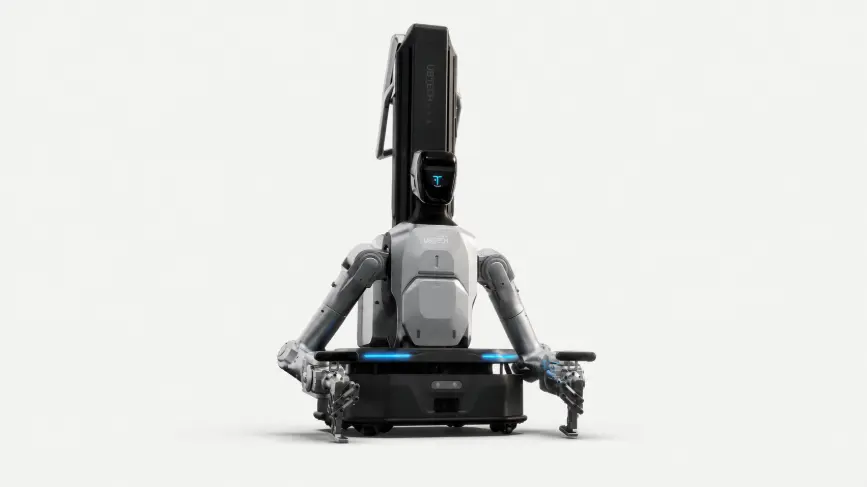
An industrial platform with vertical lifting, omnidirectional wheels, load support and interchangeable end effectors. Designed for repetitive handling, palletising and machine-loading cycles.
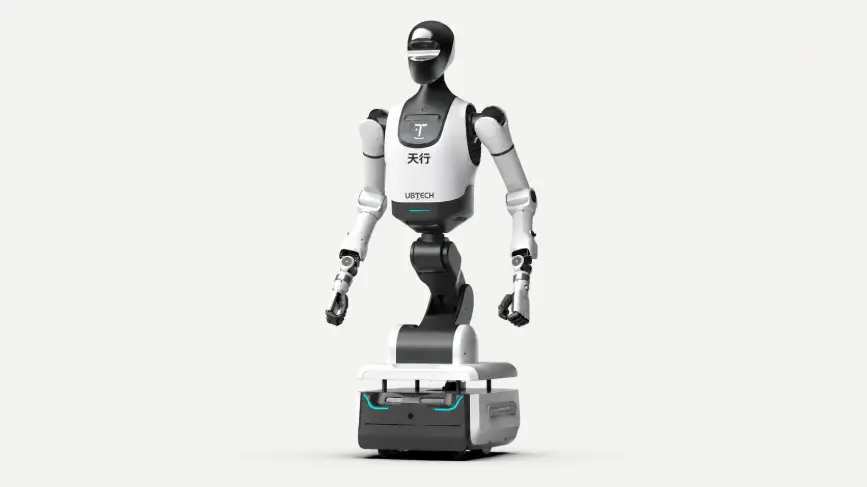
An embodied-AI assistant with adjustable height, 7-axis arms, hands or grippers, and the ability to operate buttons, lifts, doors and equipment without modifying the environment.
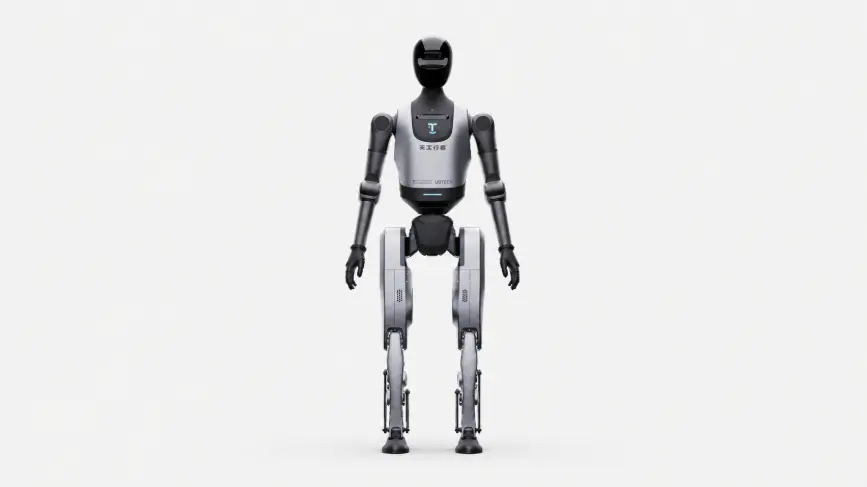
A full-size platform for research, advanced education and development of mobility, interaction and embodied intelligence, with motor and sensor control accessible to the integrator.
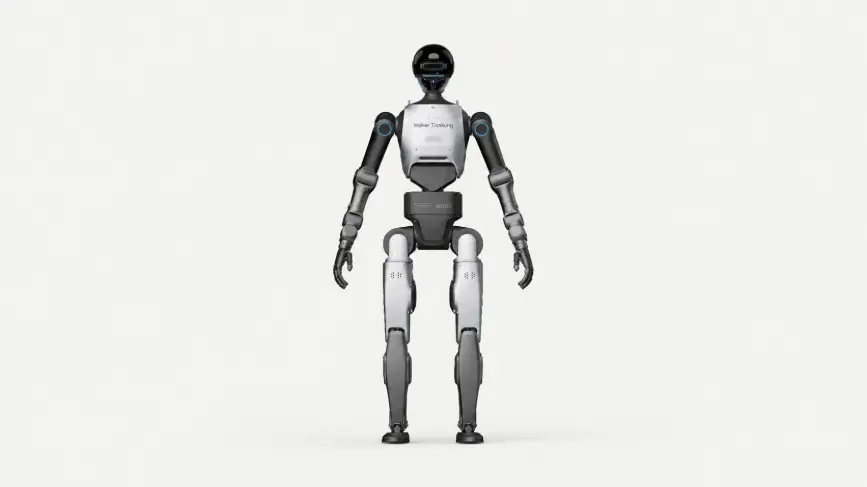
A configuration focused on dexterous manipulation and embodied-AI research. It adds hands, perception and fine control to the Tienkung platform to develop tasks with richer motor capabilities.
Quick comparison
| Plataforma | Mobility | Carga | Autonomia | Integration | Melhor ajuste |
|---|---|---|---|---|---|
| Walker S2 | Bípede, 2 m/s | Up to 15 kg | Dual-battery management | ROSA 2.0, rede industrial, Co-Agent | Flexible production and whole-body tasks |
| Cruzr S2 | Wheels, turning within 0,8 m | Up to 15 kg | Up to 8 h in inspection | ROS/ROSA, Wi-Fi, Ethernet | Inspection, SPS, logistics and service |
| Cruzr Y1 | Omnidirectional base + lifting | 10 kg | >4 h | MES, ERP, WMS, fleet management | Boxes, pallets, sorting and machines |
| Sky Walker | Wheels + variable height | 4,5 kg/arm; 16 kg max. | 4 h | ROS 2, teleoperation, OTA | Rounds, remote operation and reception |
| Walker Tienkung | Bipedal, up to 10 km/h | R&D configuration | 3 h contínuas | ROS 2, API completa, EtherCAT | Research, education and embodied AI |
| Tienkung DEX | Bípede | Manipulation-focused | Depending on configuration | ROS 2, VLA/VLM, API aberta | Dexterous manipulation and datasets |
Catalogue specifications. Values depend on version, end effector, battery, software and cycle conditions. Application analysis confirms the final configuration.
Applications
The project combines robot, end effector, perception, safety, software and process integration. Actual capability comes from the complete system.
Boxes, trays, containers and parts between supermarket, line and station, with tolerance for displacement and missing items.
CNC machines, presses, benches and lines with 3D recognition, dedicated grippers and dynamic pose correction.
Visual, thermal and multimodal inspection, evidence recording and integration of results with quality systems.
Bimanual operations, insertion, fixturing and tools with controlled force and motion planning.
Reading instruments and operating buttons, doors and lifts, with teleoperation for exceptions or hazardous areas.
LLM interaction, knowledge content, navigation, presentations and support tasks in public spaces.
Casos de uso industriais UBTECH
Integration
A useful humanoid needs to understand the task, navigate safely, manipulate the correct object and communicate with the factory. NM3D structures the project from feasibility to production support.
Additional UBTECH portfolio
In addition to the Humatrix range detailed above, the UBTECH family includes industrial and commercial platforms suited to specific projects, regional availability and configuration.
Information consolidated from Humatrix/UBTECH technical catalogues and official pagesHumatrixeUBTECH Robotics.
Como avançamos
Frequently asked questions
Video of the current cycle, parts and weights, dimensions, throughput, layout, access, equipment and automation objective. The more representative the sample, the better the analysis.
Yes, provided the project includes interfaces, signals, safety and exception handling. PLC, MES, ERP, WMS, AMR, doors, lifts and APIs can be integrated.
No. Legs are valuable in environments designed for people; wheels can offer greater operating autonomy, stability and throughput on industrial floors. The task determines the choice.
Yes. R&D platforms provide ROS 2 and control interfaces. On industrial platforms, the level of openness and certification depends on the package and project.
Depending on the platform, options include automatic charging, replaceable batteries and intelligent energy management. The design considers the cycle, priorities and contingency arrangements.
The project can include installation, training, maintenance, skill updates, remote assistance and support as the process evolves.
Iberian humanoid robotics integration
Specialising in the sale, integration and support of humanoid robotics and artificial intelligence, Humatrix supports businesses and institutions from task assessment to implementation and development of the solution.
Próximo passo
Send a video of the cycle, the part, payload and production rate. We assess the most suitable architecture and define an objective trial.